Hunan University
Master’s student · Autonomous driving
Research team of Academicians Zhihua Zhong and Rongjun Ding
Data Lead & Algorithm Expert · Pokebot
From autonomous driving to embodied intelligence.
I have seven years of experience developing autonomous-driving algorithms, spanning perception and prediction and the full workflow from data and model training to deployment. I am now a Data Lead and Algorithm Expert at PokeBot, contributing to RoboAPI development and leading data work and embodied foundation-model pretraining in collaboration with Huazhe Xu.
During my internship at TuSimple, I collaborated with Lue Fan, Feng Wang, and Naiyan Wang on 3D perception research and co-authored CTRL (ICCV 2023 Oral). CTRL achieved SOTA on both the Waymo Open Dataset 3D Detection and 3D Tracking leaderboards in the 2023 paper’s offline evaluation, providing a high-accuracy approach to industrial 3D object auto-labeling.
At Horizon Robotics, I worked with Xuewu Lin and Zhizhong Su and led stereo vision algorithm development, translating research into engineering implementations that supported production deployment.
At LimX Dynamics, I reproduced the towel-folding capability shown in DYNA-1’s public videos, achieving faster folding than the demonstrations in those videos. This research led to ARM, on which I am first author, with code released through FluxVLA.
My work connects algorithm research, data, model training, and deployment to build reliable intelligent systems. If my work interests you, I welcome conversations about research, technical collaboration, and career opportunities.
Master’s student · Autonomous driving
Research team of Academicians Zhihua Zhong and Rongjun Ding
Joint master’s training
Research team of Academician Keqiang Li
Intelligent and Connected Vehicles research group; co-advised by Ming Gao.
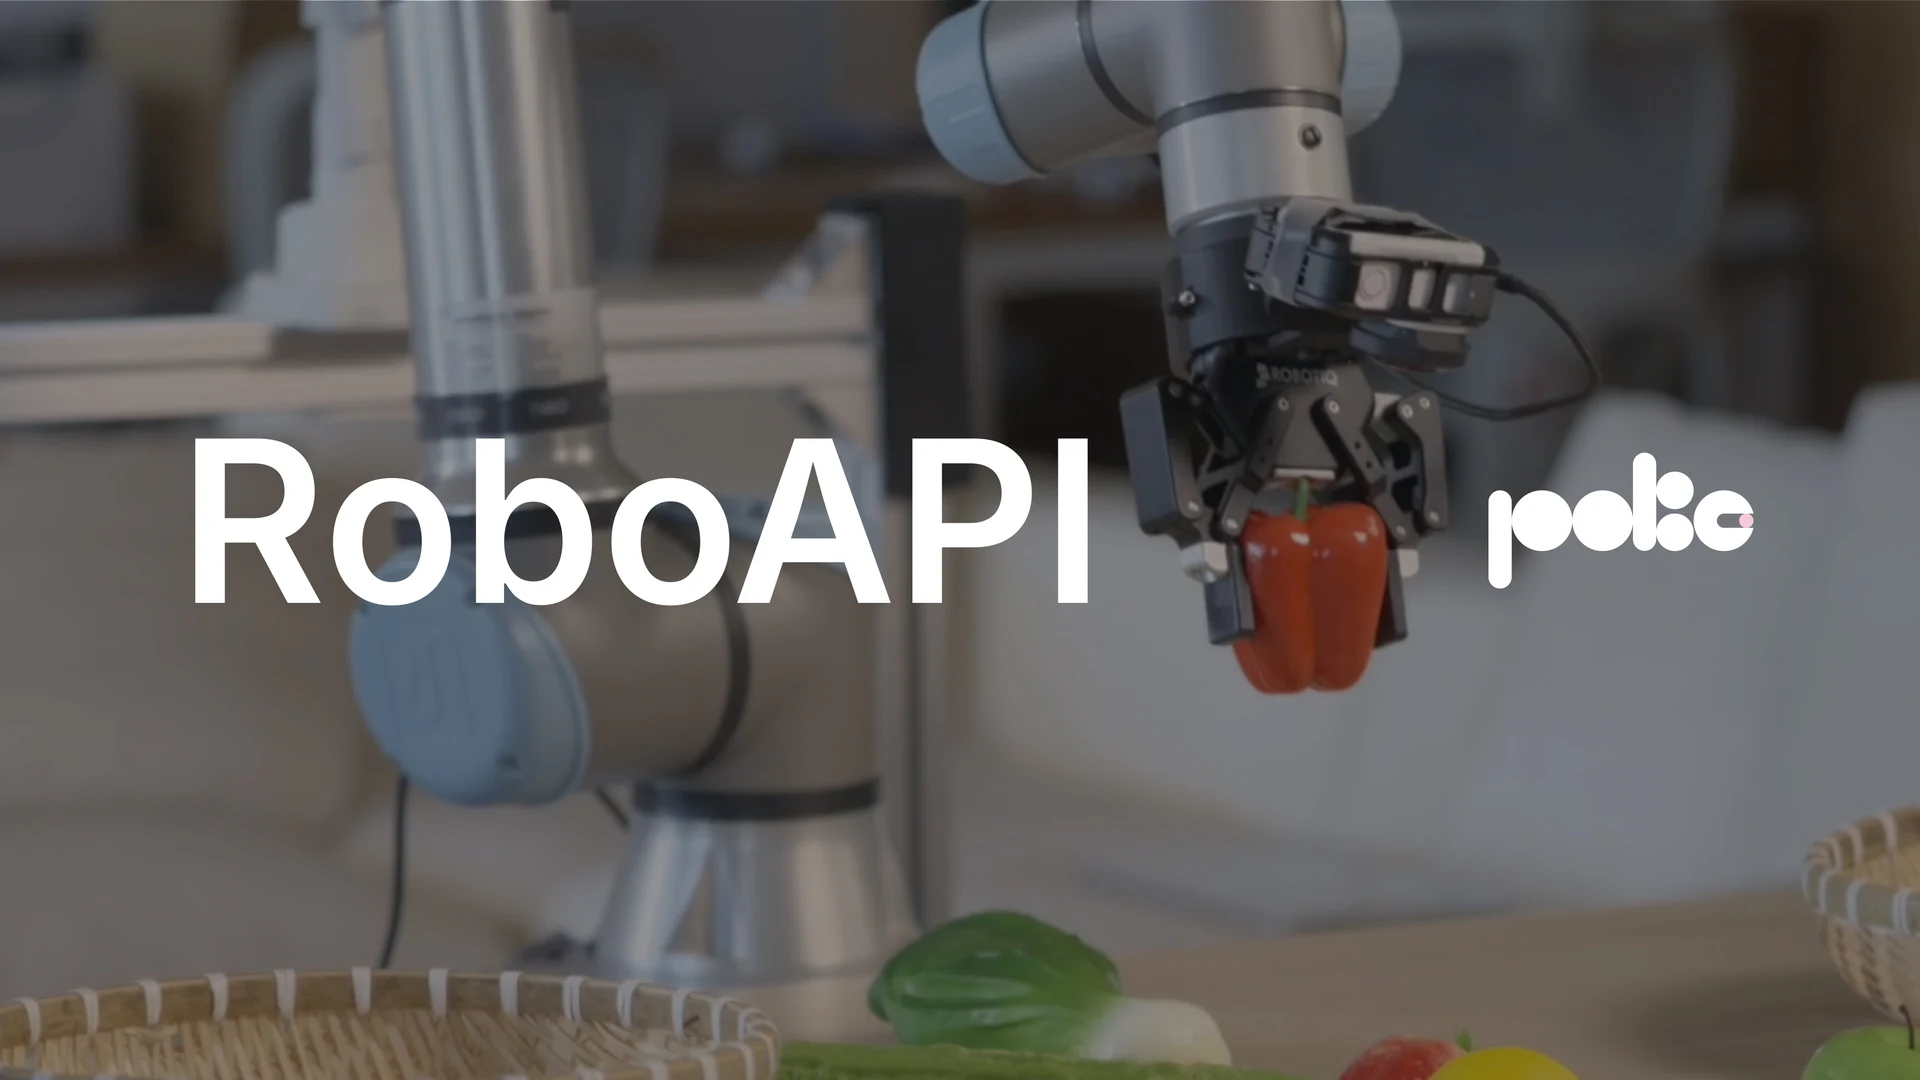
Industry project · October 2026
A robot API powered by the Poke-Aurora world-action model, translating visual observations, robot state, and language instructions into action chunks for zero-shot manipulation across environments and robot configurations.
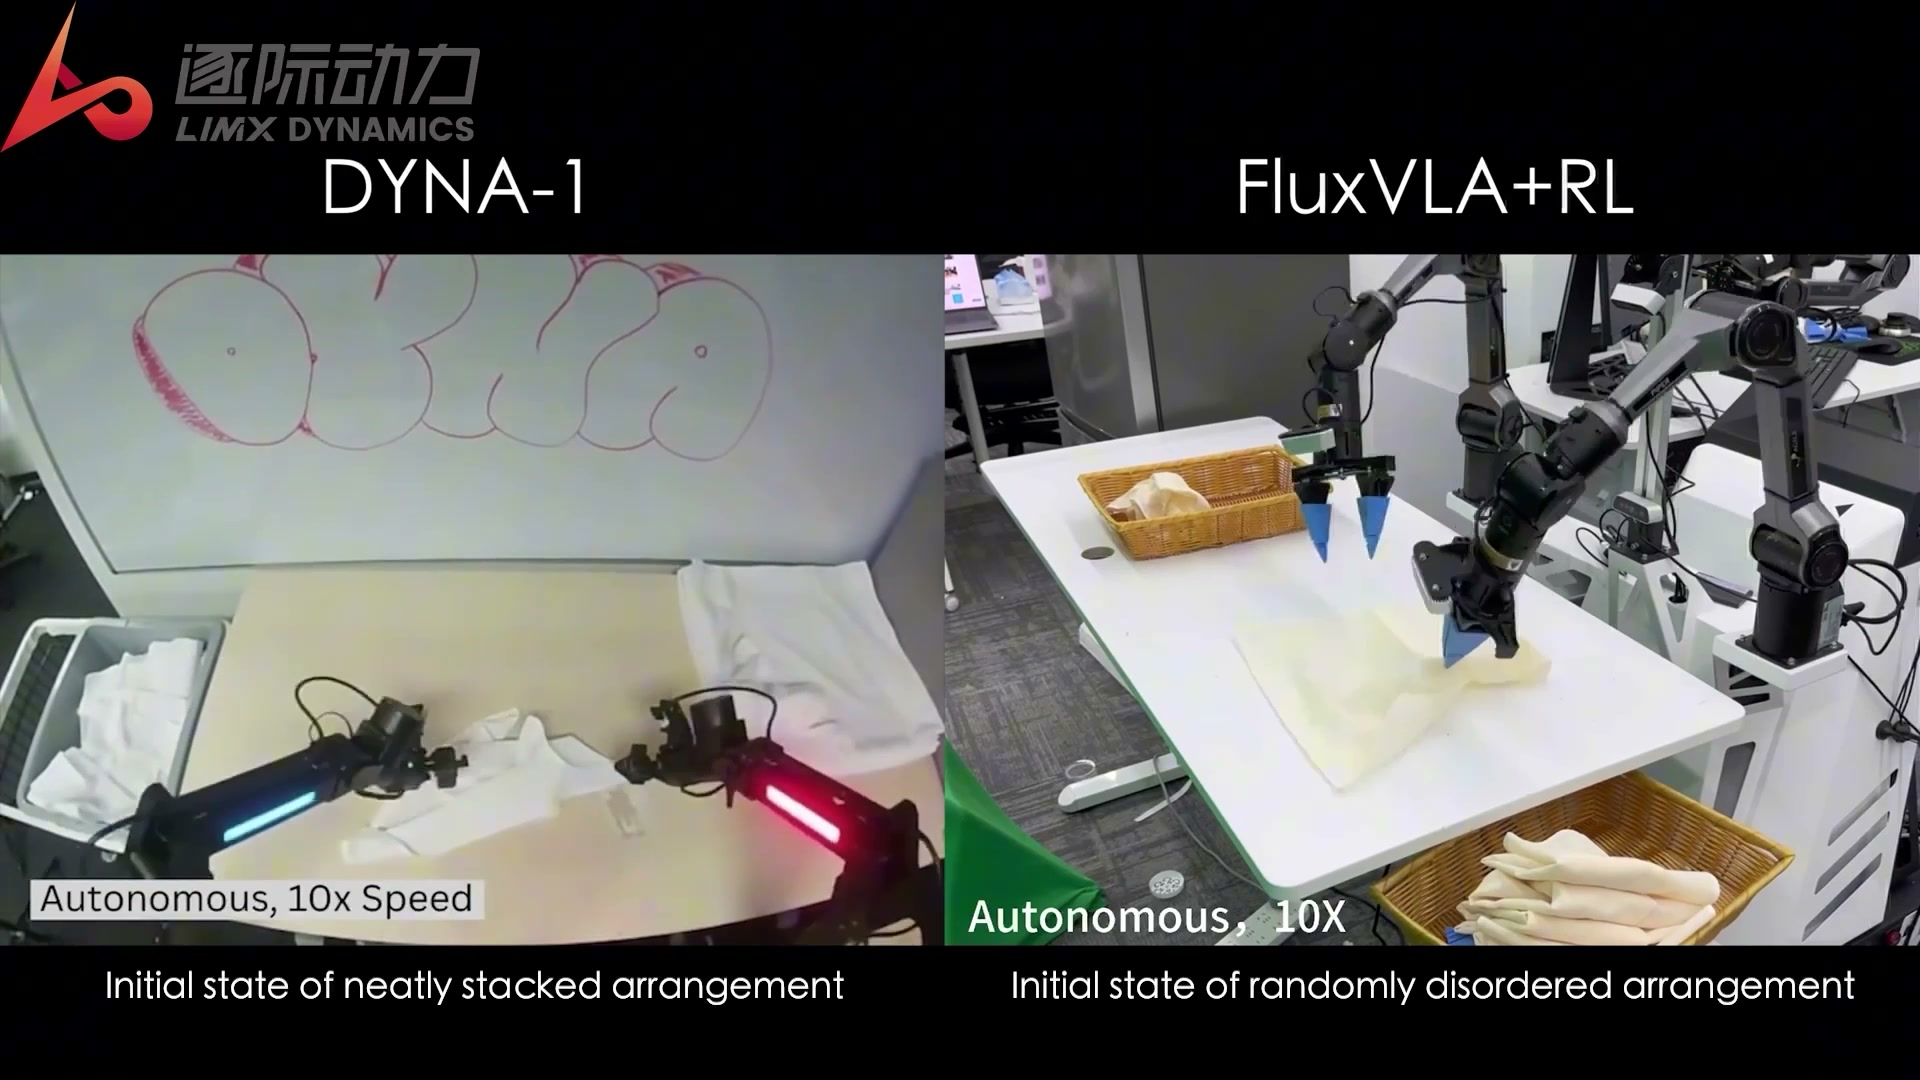
CVPR 2026 Workshop · Poster
Learning relative advantage from three simple labels—progressing, regressing, and stagnant—to guide policy training for long-horizon manipulation.
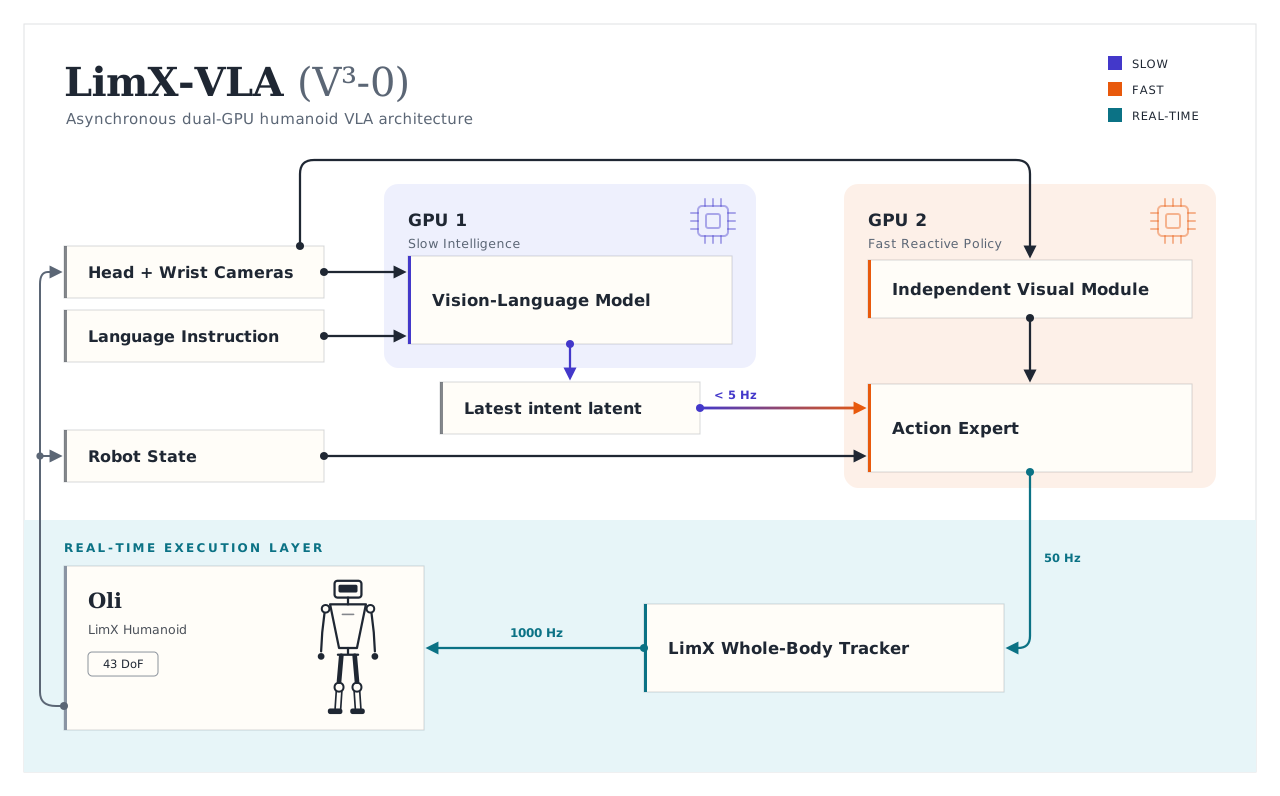
Industry project · 2026
The V³-0 stack in COSA 0.5 combines humanoid whole-body mobile manipulation with human-in-the-loop reinforcement learning on real robots.
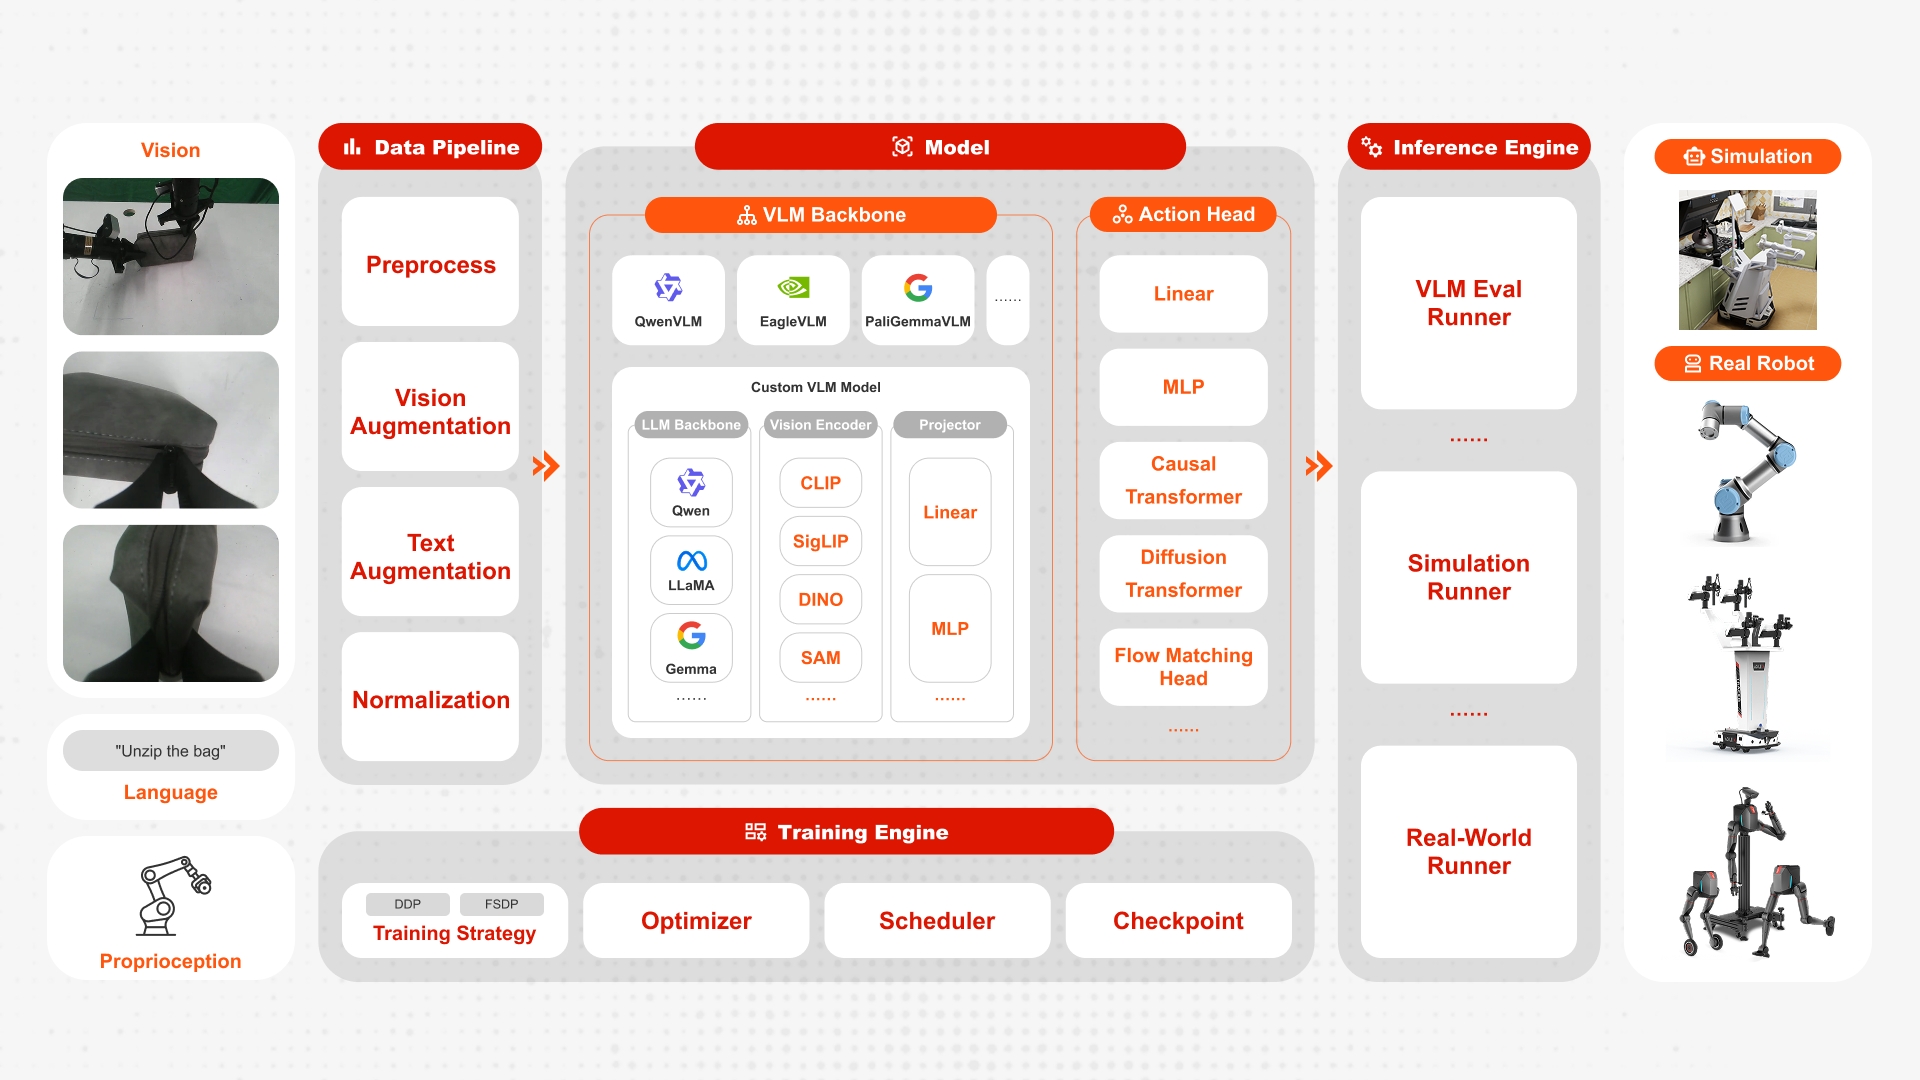
arXiv technical report · 2026
A modular engineering platform connecting embodied-policy data, training, simulation evaluation, and real-robot deployment.
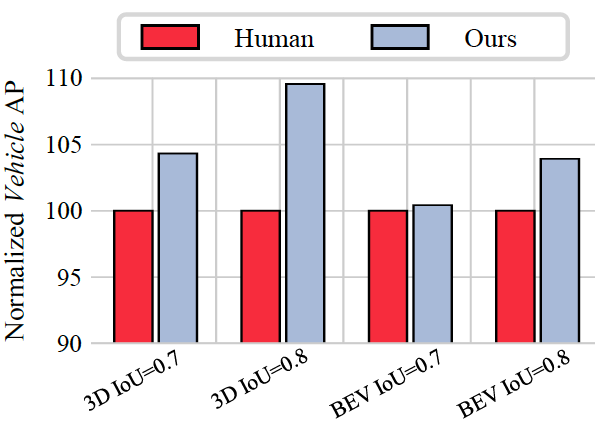
ICCV 2023 · Oral
Track-centric offline LiDAR 3D detection, combining bidirectional tracking and temporal refinement to improve automatic annotation.
Official documentation for connecting robots, calling the model API, and running manipulation tasks with RoboAPI.
Open-source infrastructure for embodied-policy data, training, evaluation, and deployment. Includes VLA/WAM integration and inference workflows.
The official implementation of CTRL is maintained in tusen-ai/SST. The repository includes training and evaluation instructions.
Project overview, manipulation demonstrations, method details, and experimental results for ARM.
Embodied Foundation Model Algorithm Researcher
Reproduced the towel-folding capability shown in DYNA-1’s public videos, achieving faster folding than the demonstrations in those videos. This research led to ARM, which I first-authored and open-sourced through FluxVLA.
Worked on reinforcement learning and humanoid loco-manipulation, and provided support for data, models, and selected algorithms in COSA 0.5.
Autonomous-driving Algorithm Researcher
Worked with Xuewu Lin and Zhizhong Su, leading stereo vision algorithm development and supporting deployment in production programs. My work also covered general perception, occupancy, world models, and end-to-end driving. Mentored by Xuewu Lin.
Autonomous-driving Algorithm Research
Collaborated with Lue Fan, Feng Wang, and Naiyan Wang on 3D perception research, co-authoring CTRL (ICCV 2023 Oral). CTRL achieved SOTA on both the Waymo Open Dataset 3D Detection and 3D Tracking leaderboards in the 2023 paper’s offline evaluation, providing a high-accuracy approach to industrial 3D object auto-labeling.
During my internship, I received guidance from Yan Yan, Feng Wang, and Naiyan Wang.
Interested in my work? Let’s talk research, technical collaboration, or career opportunities.